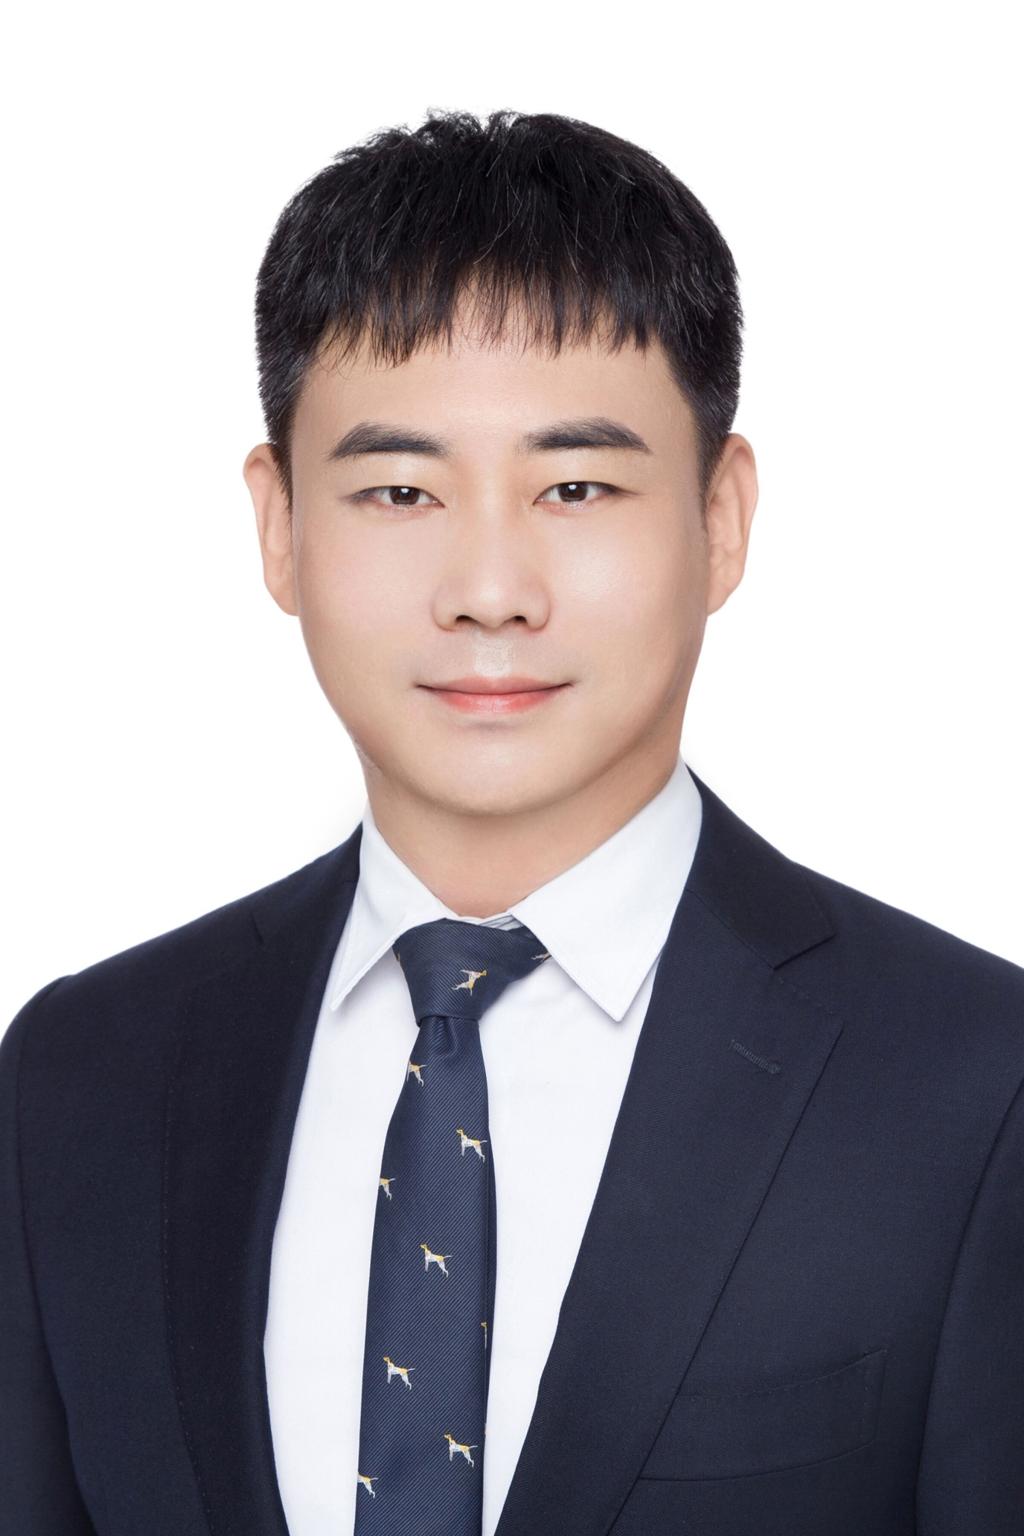
Qiong Wu
Jiangnan University, China
Qiong Wu received the Ph.D. degree in information and communication engineering from National Mobile Communications Research Laboratory, Southeast University, Nanjing, China, in 2016. From 2018 to 2020, he was a postdoctoral researcher with the Department of Electronic Engineering, Tsinghua University, Beijing, China. He is currently an associate professor with the School of Automation and Intelligent Science (School of IoT), Jiangnan University, Wuxi, China. Dr. Wu is a Senior Member of IEEE and China Institute of Communications. He has published over 1 2 0 papers in high impact journals and conferences, and authorized over 30 patents. He was elected as one of the world's top 2% scientists in 2024 and 2022 by Stanford University. He has received the young scientist award of ICCCS'24 and ICITE ' 24, as well as the best young scholar award of IoTIR ' 26 . He won the high-impact paper of Chinese Journal of Electronics award. He ha s been awarded the National Academy of Artifical Intelligence (NAAI) Certified AI Senior Engineer and Senior Research Fellow , and was the excellen t r eviewer of Computer Networks in 2024. He has severed as the editorial board member, early career editorial board member, ( lead ) guest editor for over 10 j ournals , as well as the invited speaker, TPC c hair, o rganizing c ommittee c hair, publication chair, special session c hair, workshop chair, TPC member and session chair for over 3 0 international c onferences. His current research interest focuses on vehicular networks, autonomous driving communication technology, and machine learning.
In this talk, we present a mobile computing-based framework for distributed computing and cooperative control of connected and automated vehicles (CAVs) in ramp merging scenarios under intelligent transportation systems (ITS). A centralized trajectory planning problem is first formulated to optimize merging efficiency and safety. To eliminate reliance on a central controller, a distributed solution is developed using Alternating Direction Method of Multipliers (ADMM) algorithm based on Vehicle-to-Everything (V2X) communication, enabling CAVs to collaboratively compute trajectories in parallel by leveraging their onboard computing power. Building on this, a multi-vehicle model predictive control (MPC) problem is proposed to enhance system stability under strict constraints. To solve it efficiently, a Distributed Cooperative Iterative MPC (DCIMPC) method is introduced, which decomposes and reformulates the problem for real-time distributed execution across CAVs. Together, these methods form a mobile edge computing-driven control framework. Simulations and experiments demonstrate significant improvements in computational efficiency and system performance, highlighting the potential of mobile computing in cooperative CAV control.